
Exoskeleton Architecture
Conforms to hand kinematics and provides a stable platform for multimodal sensors.
Exoskeleton multimodal hand capture with full-palm touch for dexterous teaching
Liv Dex combines full-joint encoders, near-hand vision, IMU and full-palm touch. DataCube hardware synchronization delivers high-fidelity hand data for dexterous teaching and dataset creation.
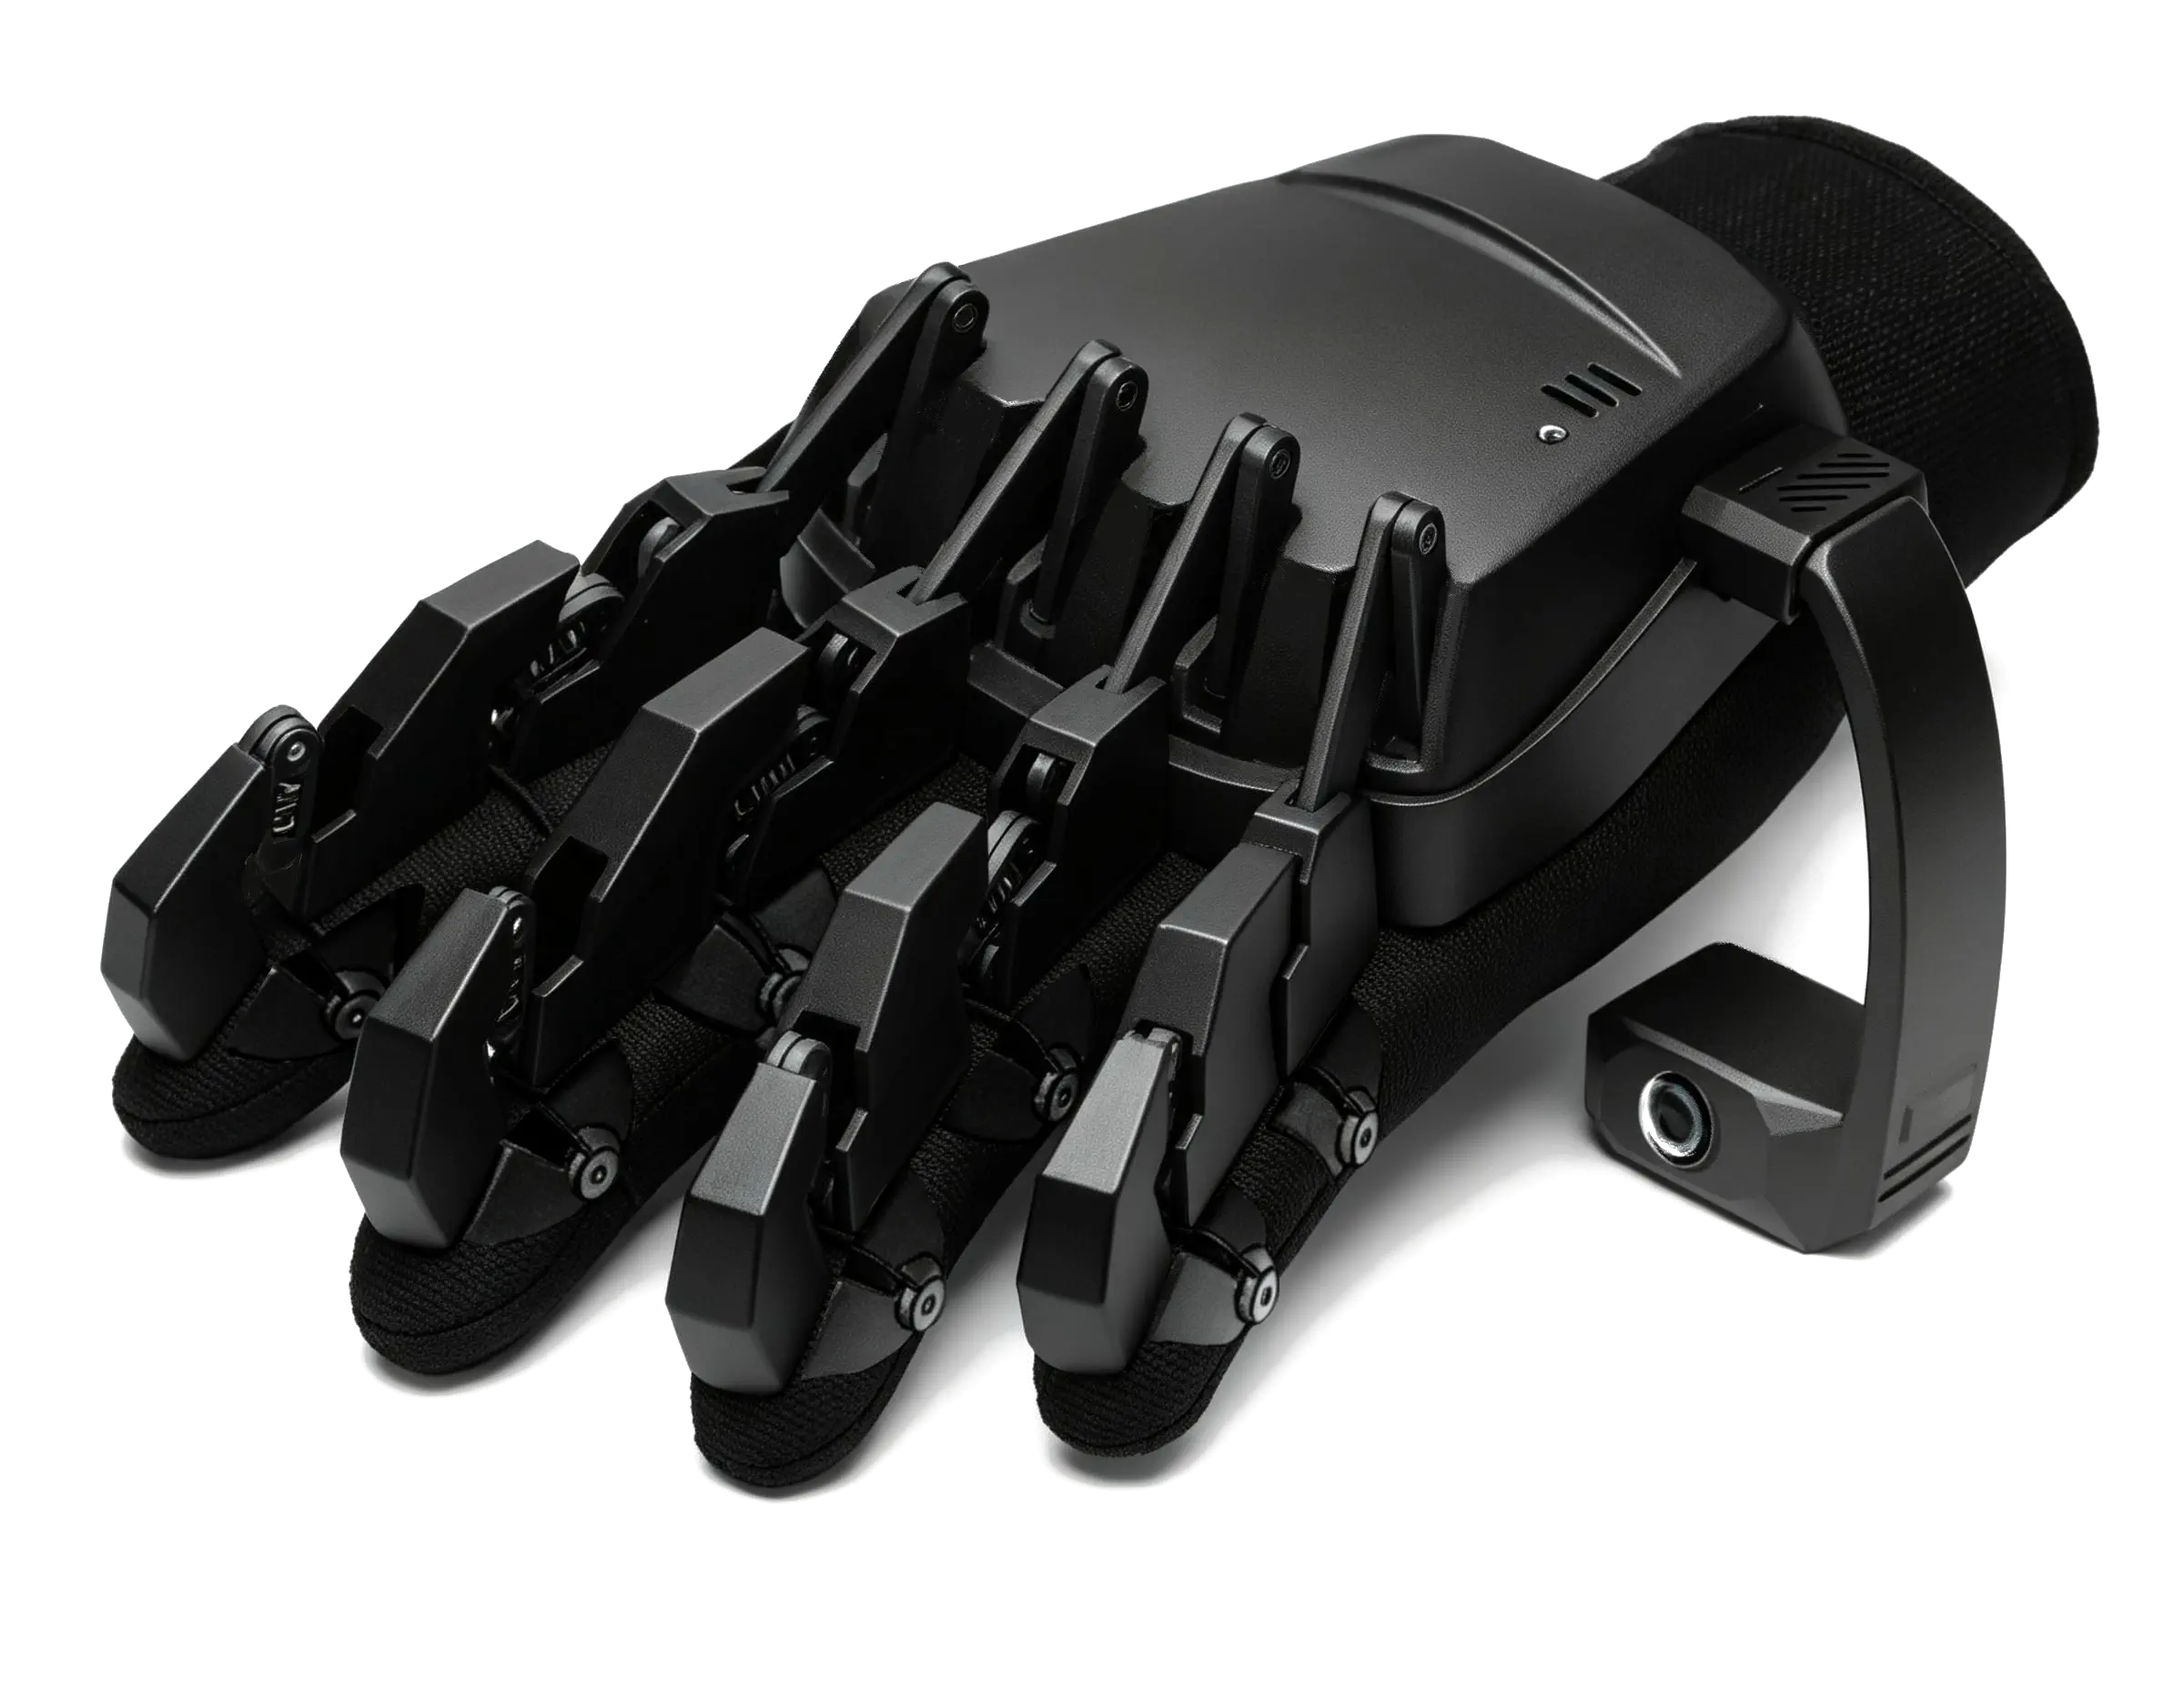
Conforms to hand kinematics and provides a stable platform for multimodal sensors.
High-precision angle capture across 21 joints reconstructs fine manipulation.
Near-hand vision captures contact deformation while full-palm sensing measures contact force and distribution.
DataCube aligns vision, joint, IMU and tactile streams.
High-frequency joint angles, near-hand vision and dense touch reconstruct fine hand movements.
Our solution team can provide product demos, trials and custom integration support for your application.
Book a Product Consultation