
Simple Operation
Operate through the UMI touchscreen, a host computer and other supported control methods.
Handheld human-centered capture that starts model evolution with real interaction
LivUMI is LivSyn's dual-gripper terminal for embodied intelligence data collection. It combines multi-view vision, IMU, gripper position and touch to produce high-quality demonstrations for model training.
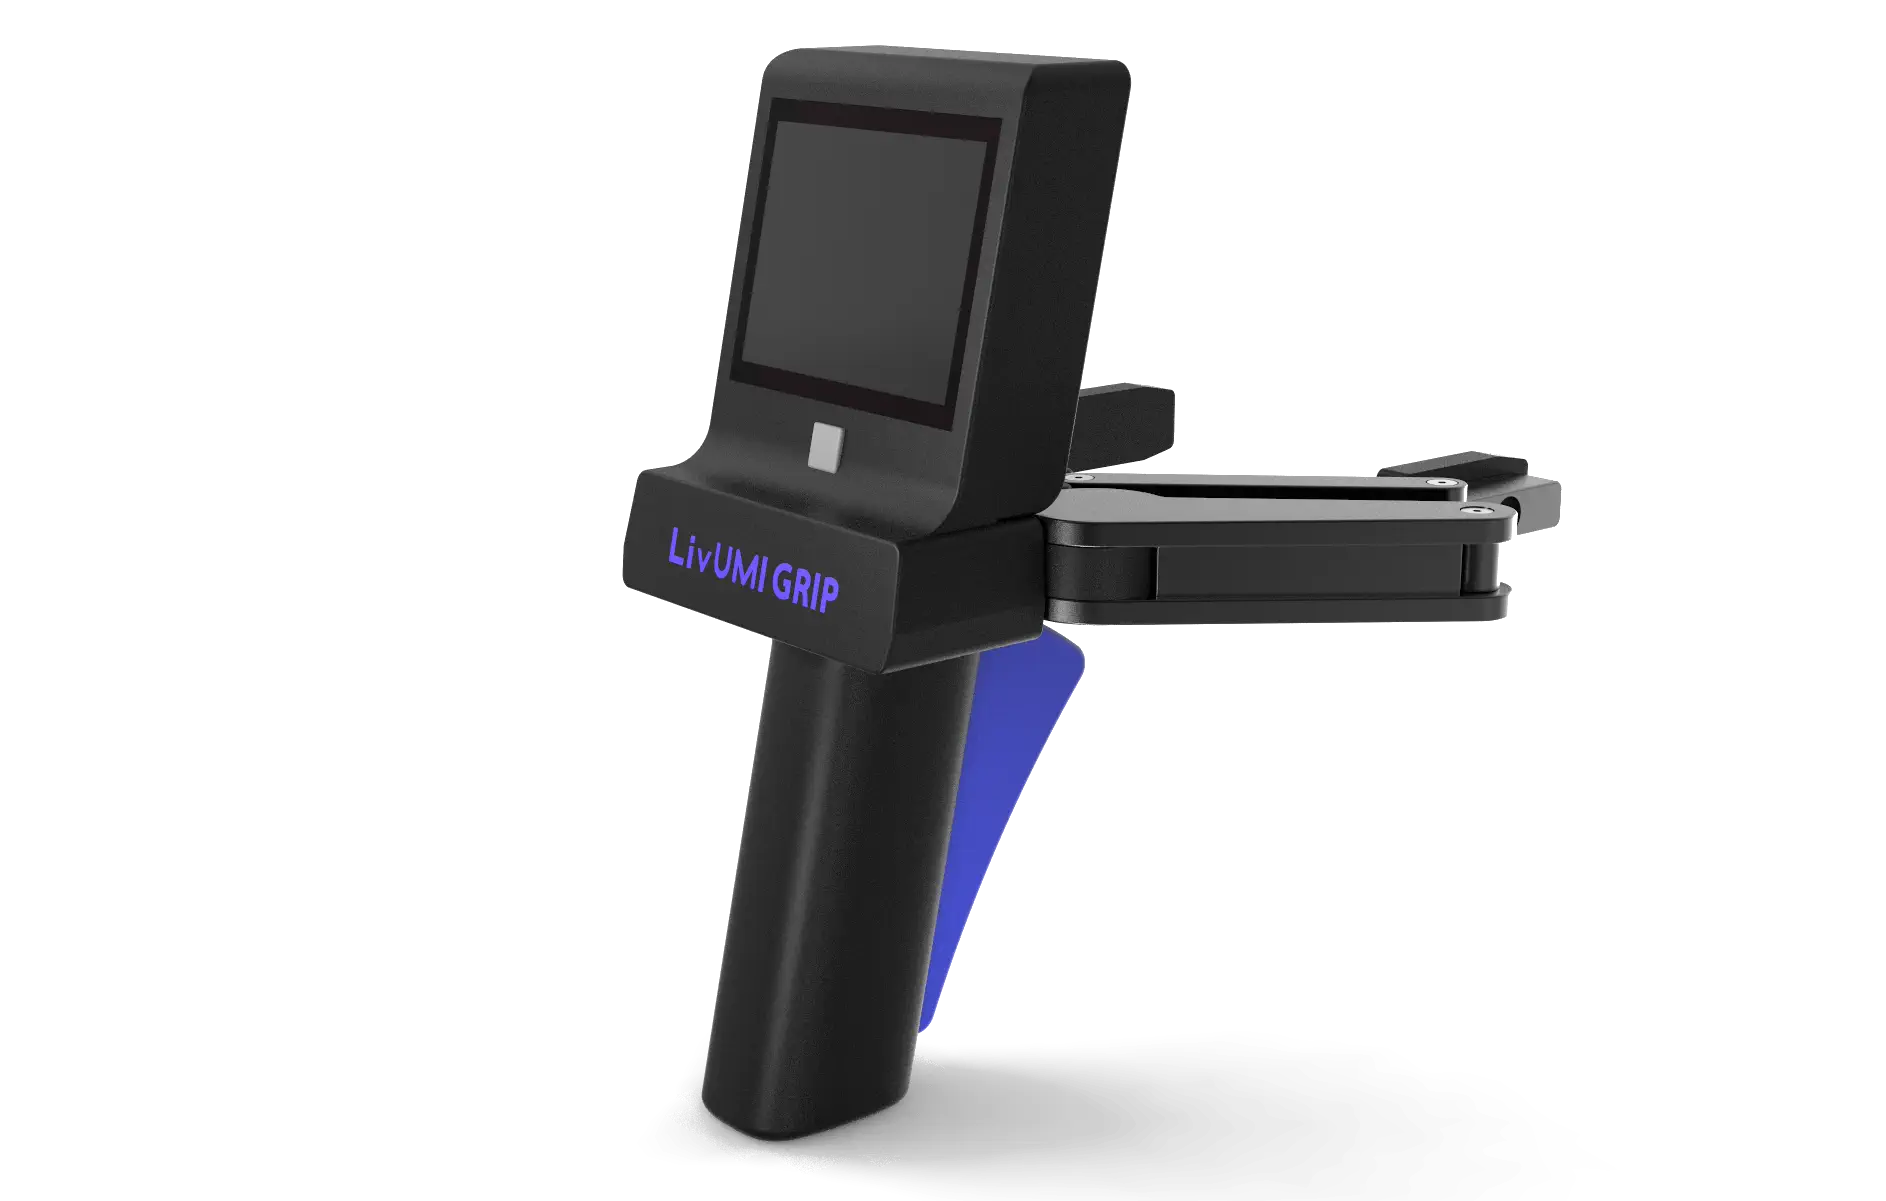
Operate through the UMI touchscreen, a host computer and other supported control methods.
Collect data in fixed installations or outdoor environments.
1ms hardware-level multisensor fusion keeps data streams synchronized.
Calibration delivers high-accuracy spatial trajectories for action reconstruction.
Record gripper position, gripping force and tactile signals in sync.
Collect in home, industrial and service environments without a robot body.
Multimodal sensing and accurate localization provide stable, synchronized output in real manipulation tasks.
Our solution team can provide product demos, trials and custom integration support for your application.
Book a Product Consultation